Monday, May 22, 2024
ADAS Sensor Fusion Logic for Real-World Edge Cases
by
Published
Views:
ADAS sensor fusion logic is what turns scattered camera, radar, and lidar inputs into reliable driving decisions—especially when real-world edge cases challenge visibility, timing, and object classification. For operators and users, understanding how this logic works helps explain why advanced driver assistance systems respond differently across complex road conditions, and why robust fusion design is essential for safer, more dependable mobility.
Most users searching for adas sensor fusion logic want a practical answer, not a research lecture. They want to know why the system behaves confidently in one moment, hesitates in another, and occasionally issues warnings that seem late or overly cautious.
For operators, the core truth is simple: fusion logic is not just combining sensors. It is the decision framework that weighs conflicting evidence, filters noise, tracks moving objects, and chooses when a vehicle should warn, brake, steer, or do nothing.
That matters most in edge cases. A clean highway with bright lane markings is easy. A wet urban street at dusk, with parked vans, reflective signs, road spray, and cyclists moving unpredictably, is where sensor fusion quality becomes visible.
What operators really need to know about ADAS sensor fusion logic
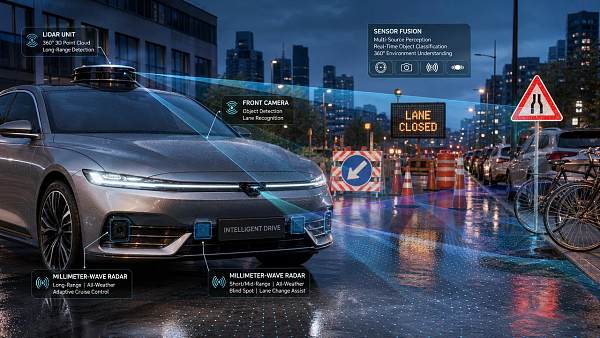
From a user perspective, the most important question is not how many sensors a vehicle has. It is whether the adas sensor fusion logic can still make stable decisions when one sensor becomes uncertain, blocked, delayed, or partially wrong.
Camera systems may struggle in glare, darkness, fog, or heavy rain. Radar may detect range and speed well, but can misinterpret stationary structures, metallic clutter, or closely spaced objects. Lidar, where used, can add geometric precision yet still face limitations from weather, contamination, and cost-driven resolution tradeoffs.
Fusion logic exists because no single sensor tells the whole story. The vehicle must compare inputs, check whether they agree in time and space, assign confidence scores, and decide which data stream deserves more weight under current conditions.
For everyday users, this explains why the same ADAS feature may feel smooth on one road and conservative on another. The visible feature is lane keeping or automatic emergency braking, but the hidden performance comes from the quality of the fusion architecture underneath.
Why edge cases are the real test, not normal driving
Manufacturers can demonstrate good ADAS behavior under standard test conditions, but real-world driving includes unusual combinations that do not appear neatly in basic certification scenarios. These are the moments where fusion design separates resilient systems from fragile ones.
An edge case is not always dramatic. It can be a motorcycle partly hidden behind a truck, a pedestrian stepping out from a shadow, a lane line faded under construction dust, or a stopped car positioned just beyond a crest.
In such situations, sensors often disagree. The camera may classify a shape as uncertain. Radar may see movement but not object type. Lidar may produce a sparse or partially blocked point cloud. Fusion logic must then decide whether to maintain, downgrade, or escalate system confidence.
If the logic is too aggressive, false positives increase and users lose trust. If it is too conservative, the system reacts too late. Good adas sensor fusion logic balances caution with usability, especially where ambiguity cannot be eliminated.
How sensor fusion actually works in a vehicle decision chain
Although implementations differ, most systems follow a common process. Sensors first capture raw or preprocessed data. The system then aligns this information across time, vehicle position, and environmental context before trying to identify what each object might be.
Next comes association. The system checks whether the radar target, camera bounding box, and lidar cluster refer to the same real-world object. If they match closely enough, the vehicle creates or updates a shared tracked object with speed, direction, and confidence attributes.
Then comes decision logic. The platform asks operational questions: Is this object in the path? Is it closing quickly? Is it likely stationary, crossing, or leaving the lane? Is confidence high enough to trigger braking, steering support, or only a driver alert?
For users, this means performance depends on more than sensor quality. Timing synchronization, object tracking stability, classification rules, and fallback behavior all shape whether ADAS feels natural, hesitant, or inconsistent.
Common edge cases that expose weak fusion design
One common problem is partial occlusion. A child, cyclist, or scooter may be hidden by another vehicle until the last moment. A camera might get only a brief visual cue, while radar sees motion without clear classification. Fusion must anticipate risk before visibility becomes perfect.
Another difficult case is reflective or cluttered infrastructure. Guardrails, overhead signs, toll structures, wet roads, and metal fencing can create radar reflections or visual confusion. Weak logic may overreact to harmless structures or underreact to true obstacles nearby.
Cut-ins are also demanding. When a vehicle suddenly enters the lane, the system must quickly recalculate path relevance, closing speed, and safe response. Delays of even fractions of a second can noticeably change braking comfort and collision margins.
Adverse weather remains a major challenge. Rain, fog, snow, spray, dirt, and low sun reduce signal quality in different ways across sensors. The best fusion systems do not pretend certainty. They detect degraded conditions and adjust thresholds, warnings, or handover expectations.
Construction zones create a separate class of edge cases. Temporary lane markers, cones, unusual vehicle trajectories, and missing signage can confuse lane-level models. Users often interpret this as random behavior, but the root issue is often complex scene ambiguity.
Why the same ADAS feature can behave differently across vehicles
Two vehicles may both advertise lane centering, adaptive cruise control, or automatic emergency braking, yet behave very differently in complex traffic. That difference often comes from the underlying fusion logic rather than the feature label itself.
Some platforms rely heavily on camera-first perception with radar as a verifier. Others use radar-led tracking with vision for classification. More advanced stacks may add lidar, high-definition maps, occupancy grids, or learned fusion models trained on difficult scenarios.
Processing architecture also matters. Centralized fusion can create a stronger global scene model, but requires high computing performance and careful latency control. Distributed fusion may be simpler in some designs, yet can carry limitations when data must be reconciled later.
Calibration quality, sensor placement, software updates, and local tuning for regional road behavior also affect results. So when users compare systems, they should think less about marketing categories and more about consistency in uncertain environments.
What good fusion logic looks like from an operator’s point of view
Operators do not need access to the full software stack to notice strong design. The first sign is consistency. A good system does not swing between overconfidence and indecision when road conditions change moderately within normal use.
The second sign is graceful degradation. If visibility worsens, the system should communicate limits clearly, reduce authority appropriately, and avoid sudden or confusing actions. Reliable systems know when to support the driver and when to step back safely.
The third sign is stable object handling. In traffic, the system should track vehicles, cyclists, and pedestrians without frequent target jumping, phantom detections, or unnecessary braking. Smooth tracking usually reflects better sensor association and confidence management.
Another sign is sensible behavior around stationary or slow-moving hazards. Some weak systems miss objects near lane boundaries or react late to stopped vehicles. Stronger fusion logic better understands path relevance and threat progression over time.
How users and fleet operators can evaluate real-world robustness
For practical evaluation, controlled demos are not enough. Users should observe behavior in low-angle sunlight, rain, night traffic, lane merges, roadworks, dense urban streets, and situations with mixed vehicle sizes such as trucks, motorcycles, and bicycles.
Pay attention to warning timing and smoothness. Does the system identify lead vehicles cleanly after cut-ins? Does lane support remain understandable when markings degrade? Does adaptive cruise respond naturally to vehicles that slow gradually versus abruptly?
False positives also matter. If a system repeatedly alerts or brakes for overhead signs, parked cars outside the path, or roadside clutter, trust drops quickly. High trust requires both hazard sensitivity and restraint in ambiguous scenes.
Fleet managers or technical buyers should also ask about validation depth. Useful questions include how edge cases were collected, whether regional road conditions were included, how weather degradation is handled, and what fallback strategy applies when sensor confidence falls.
The role of standards, benchmarking, and cross-sector engineering insight
As ADAS becomes more dependent on software-defined perception, benchmarking matters more than headline feature lists. Technical comparison should include sensor modality mix, latency control, environmental robustness, false positive management, and object tracking under occlusion.
This is where structured intelligence platforms add value. In a multi-industry environment, lessons from automotive electronics, semiconductor packaging, imaging hardware, compute architecture, and environmental durability all influence real-world ADAS reliability.
Global Industrial Matrix approaches this challenge through cross-sector benchmarking. By connecting automotive and mobility analysis with electronics, precision tooling, environmental infrastructure, and standards-based evaluation, GIM helps decision-makers interpret performance beyond marketing language.
That broader lens is important because fusion performance is never just a software story. It depends on sensing hardware, thermal management, contamination resistance, processing capacity, validation discipline, and supply chain quality across the system of systems.
What the future of ADAS sensor fusion logic is likely to improve
Fusion is moving toward richer environmental modeling rather than simple object lists. Newer systems increasingly estimate free space, uncertainty, drivable boundaries, and object intent, making them better suited for irregular scenes and temporary road changes.
Machine learning is also reshaping fusion strategy. Instead of relying only on fixed rules, some platforms learn how to weigh sensor evidence in difficult conditions. This can improve detection in edge cases, though it also raises demands for explainability and validation.
Sensor cleaning, redundancy management, and over-the-air refinement will further improve resilience. However, no near-term system will eliminate edge cases entirely. The realistic goal is not perfection, but better uncertainty handling and safer behavior when conditions degrade.
For users, that means the best systems will increasingly feel less abrupt, less brittle, and more predictable. The strongest adas sensor fusion logic will not simply detect more. It will make better decisions when the world is messy, incomplete, and fast-changing.
Conclusion: why understanding fusion logic helps users make better judgments
ADAS performance in real traffic depends less on isolated sensor specifications and more on how the vehicle combines evidence under uncertainty. That is the real meaning of adas sensor fusion logic, and it becomes most visible when edge cases challenge perception.
For operators and users, the practical takeaway is clear. Judge systems by consistency, graceful degradation, stable object tracking, and sensible responses in difficult conditions—not by feature names alone. Real safety value appears when complexity rises, not when conditions are easy.
As vehicles become more software-defined, robust fusion design will remain central to dependable mobility. Understanding that helps users set realistic expectations, ask better technical questions, and recognize why stronger benchmarking and validation matter across the global automotive ecosystem.
The Archive Newsletter
Critical industrial intelligence delivered every Tuesday. Peer-reviewed summaries of the week's most impactful logistics and market shifts.